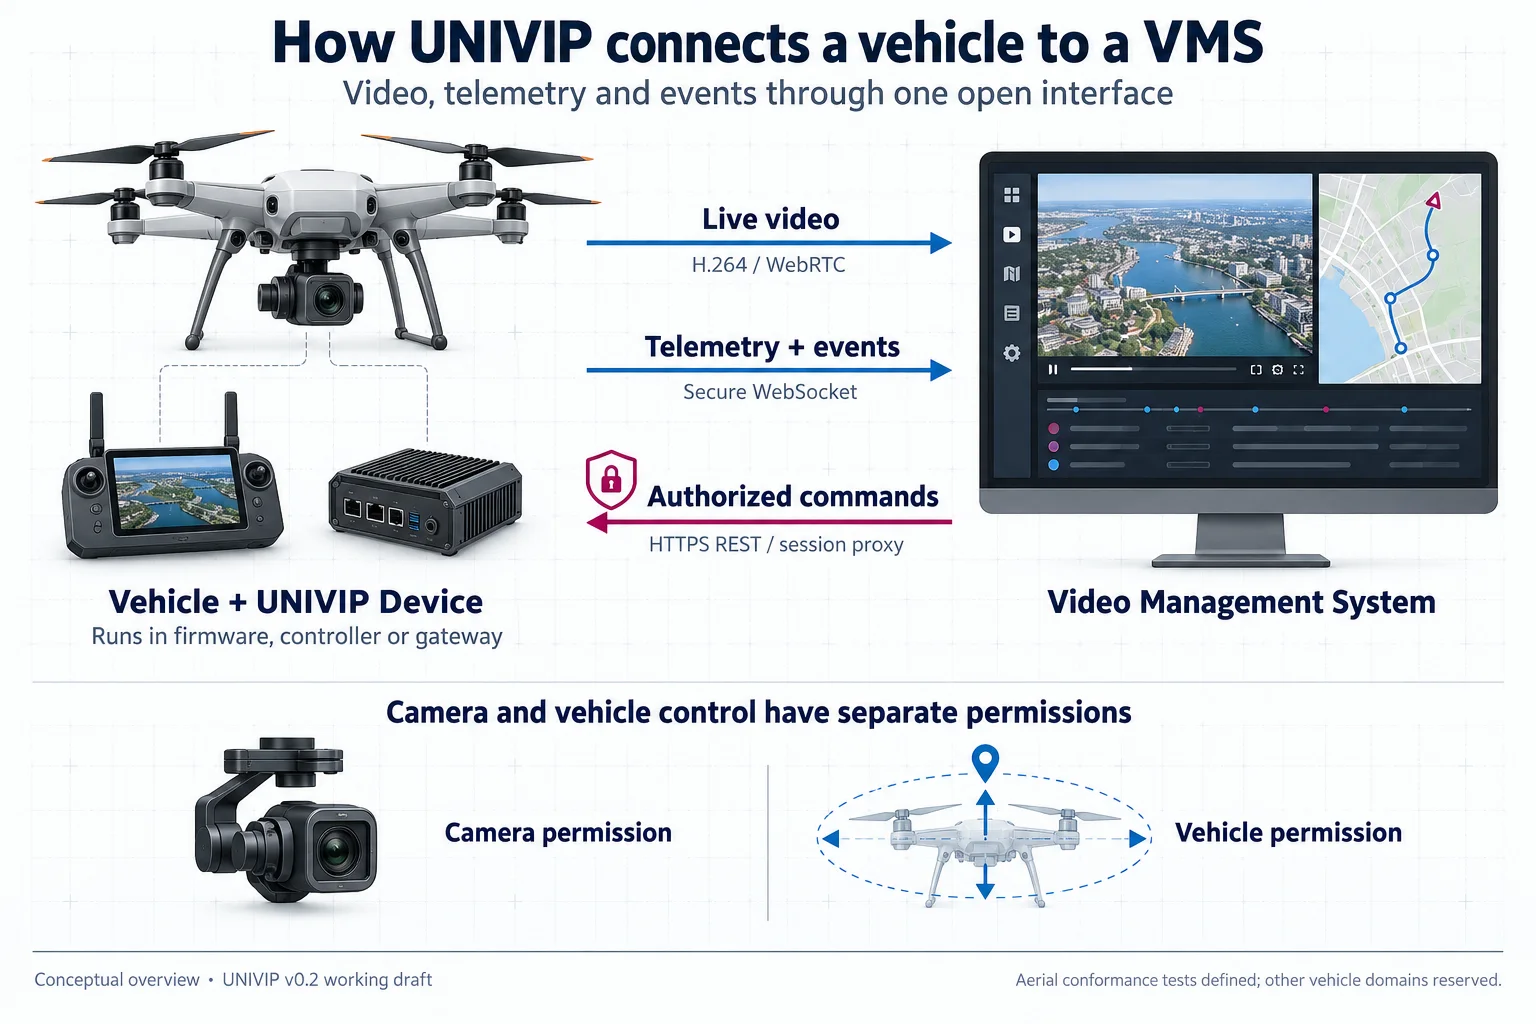
Choose a starting pointLink to the section Choose a starting point
- Build a vehicle or gateway Expose a vehicle through a native implementation, controller or adapter.
- Integrate a VMS Receive video and state, discover capabilities and offer authorized controls.
- Evaluate the proposal Review the draft, validation reports, research and roadmap.
Choose what an operator can doLink to the section Choose what an operator can do
| Profile | Provides |
|---|---|
| S — Surveillance and Streaming | Video, synchronized telemetry and events |
| C — Camera and Payload Control | S plus advertised camera and payload controls |
| N — Navigation and Vehicle Control | S plus separately authorized vehicle tasking |
C and N independently extend S. Camera control and vehicle control have separate permissions. Compare the requirements.
Project statusLink to the section Project status
UNIVIP is a v0.2 working draft with Python and .NET reference implementations. The draft defines aerial conformance tests; other vehicle domains remain reserved. Reference interoperability reports do not establish certification or readiness for operational use.